BOLTE / ARM PLATFORM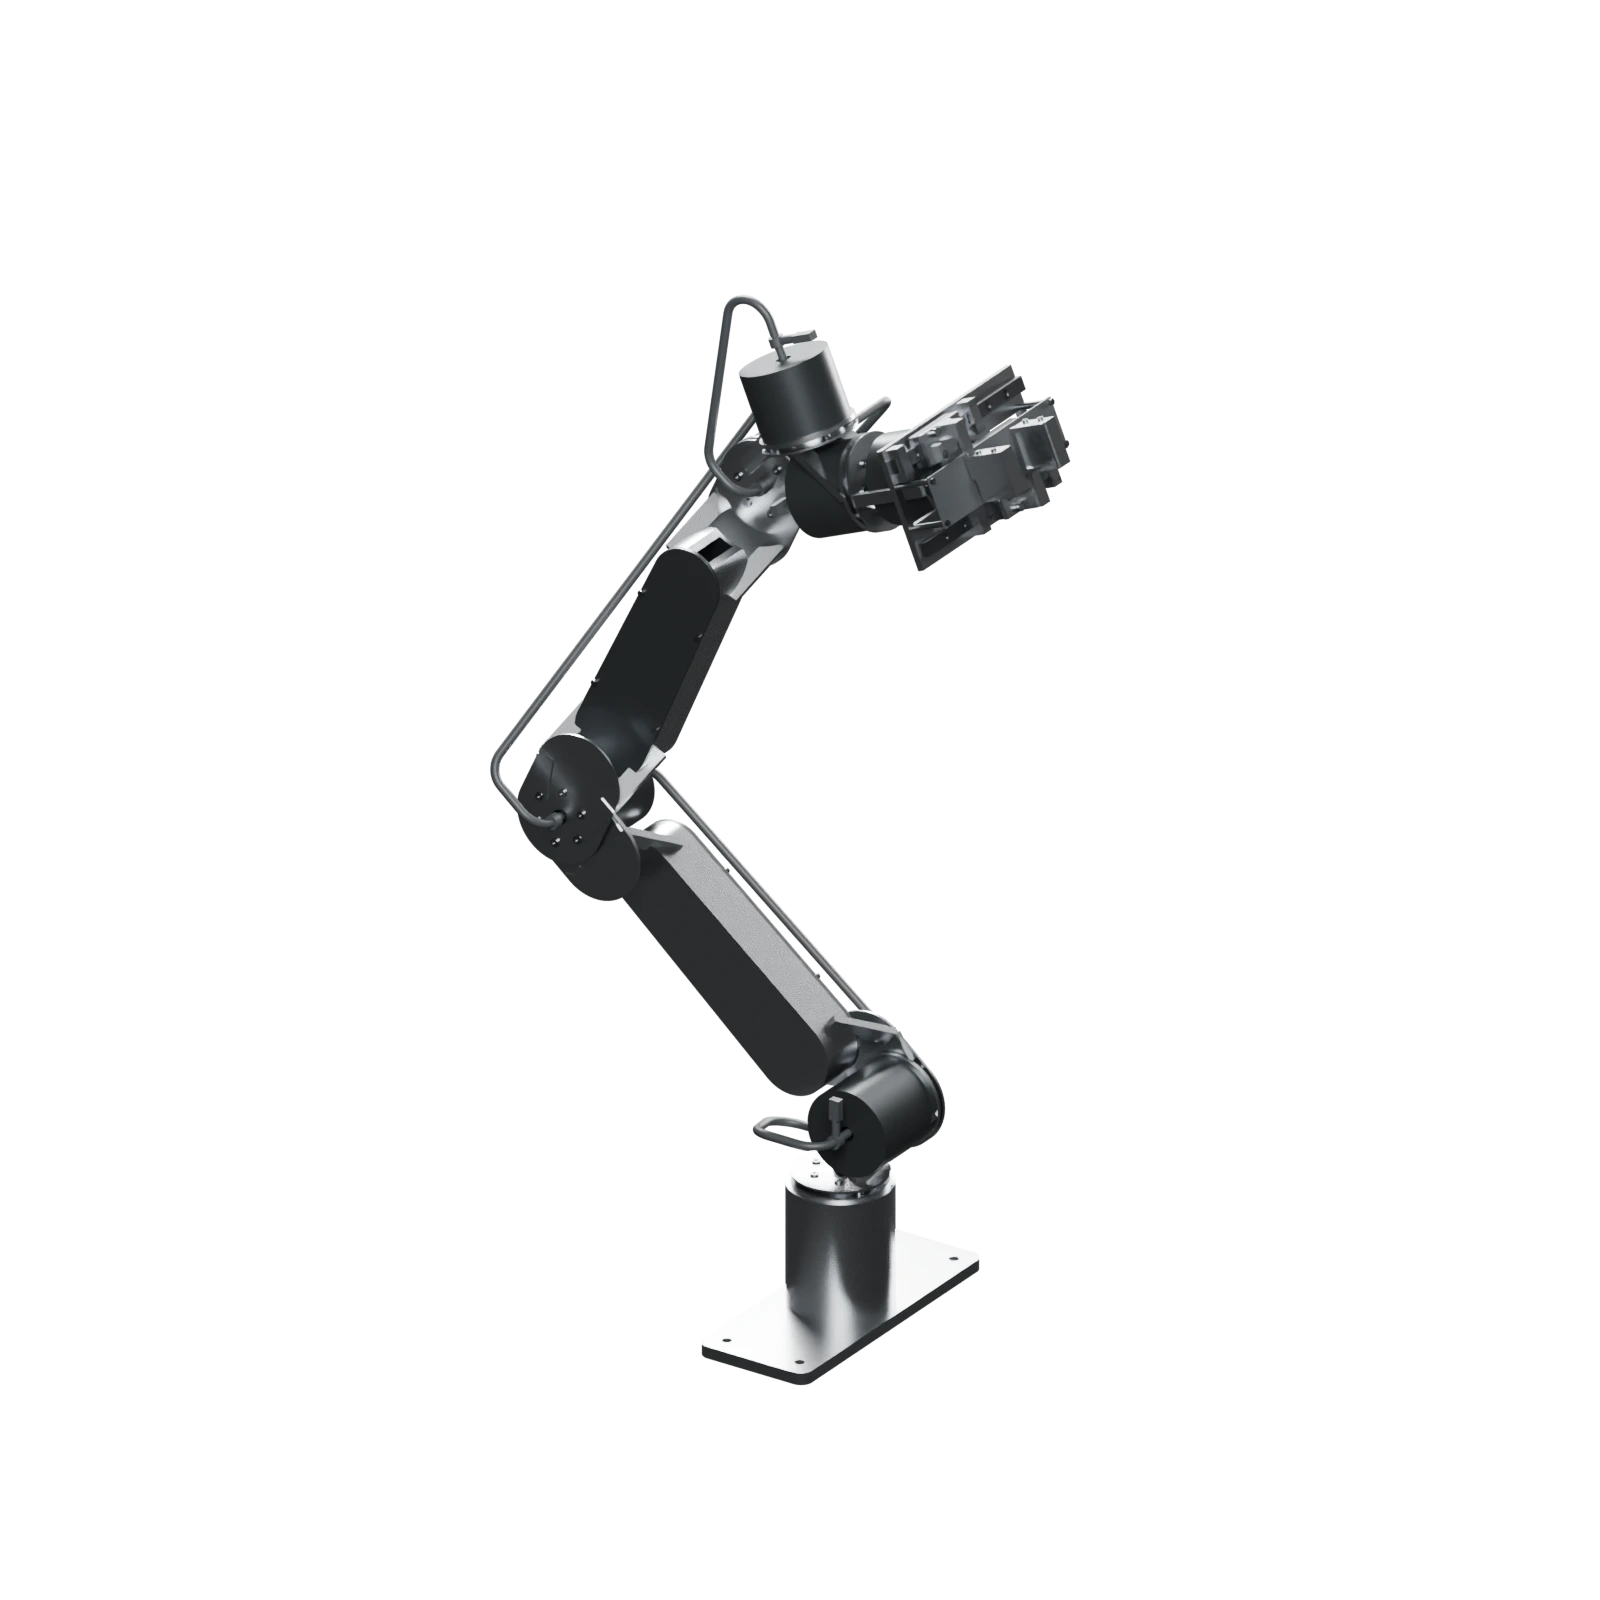
Six-axis robot arm / Development hardware
Inserter
Six-axis robot arm with seven Bolte actuators, enclosed links, a routed power and CAN-FD harness, and a Bolte gripper.
| Degrees of freedom | 6 |
|---|---|
| Payload target | 2 kgNot demonstrated. Coupled load, motion, and thermal qualification pending; excludes gripper. |
| Joint geometry | YAM v1 referenceSix reference joint transforms; Bolte tool geometry and dynamics differ. |
| Routed harness | 24 V + CAN-FDCable motion, thermal capacity, and fatigue qualification pending. |
| Repeatability target | ± 0.5 mm |
| TCP speed target | 0.25 m/s |
| Estimated mass | Under reviewCompact r3 candidate with modeled wiring; physical qualification pending. |
This interactive model shows the r3 development design. The r4 design is under engineering review. Performance specifications are development targets; assembled mass remains unqualified. Payload, speed, and repeatability require coupled qualification; the payload target does not apply at every pose.